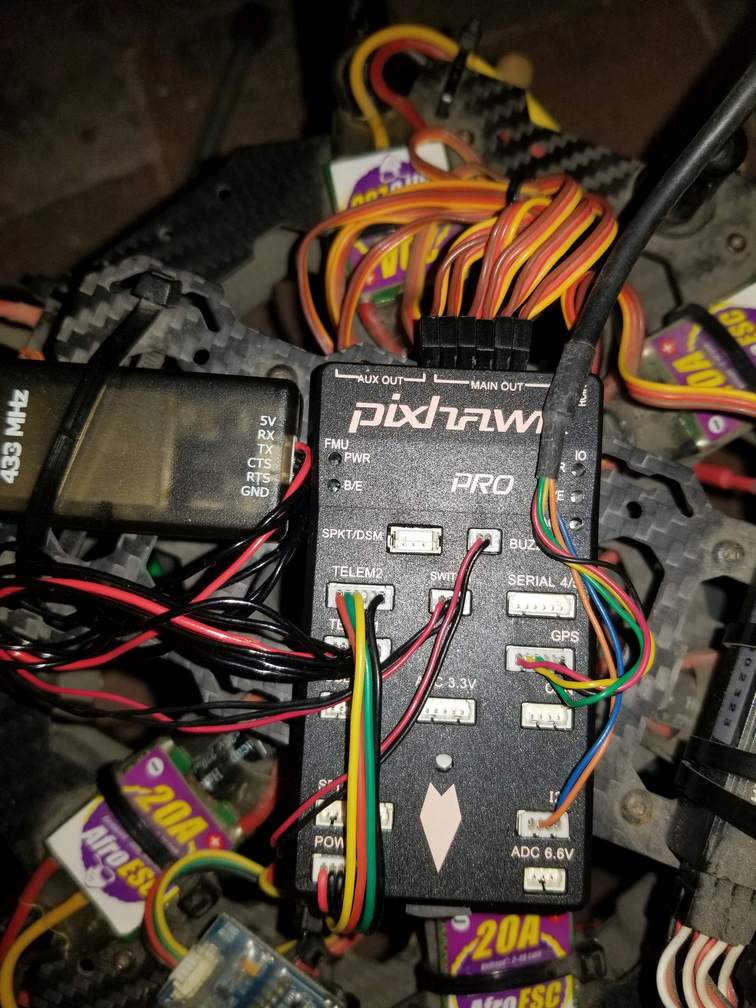
I am new to Pixhawk and drones. When exploring the Hexacopter I purchased (Tarot chassis + Pixhawk Pro set), QGC was not connecting and requiring a firmware update. I did, and it was a mistake, because it is now really impossible to connect. The symptoms are clear :
If I flash the PX4 version, I can connect, but the big led is flashing red, and configuration is not saved.
If I flash with ardupilot, I get a RAMTRON error at load and it is impossible to connect.
QGC finds this :
Found device: PX4 FMU V2
Connected to bootloader:
Version: 4
Board ID: 9
Flash size: 2080768
And offers to install :
- PX4 Pro 1.17.0 -Stable release
- Ardupilot
and if I choose Ardupilot there are different choices.
From all tests done with the help of Gemini and ChatGPT, I conclude there is nothing broken, just the firmware is not the good one. This Chinese clone is not totally compatible with the standard one, and the way the RAMTRON is initialised is probably different.
For Ardupilot, we have tried :
- Pixhawk1 - 4.7.0
- fmuv2 - 4.7.0
No difference.
When I try to connect with Mission Planner, I get an error after the timeout :
No Mavlink Heartbeat Packets where read from this port - Verify Baud Rate and setup

Mission Planner waits for 2 valid heartbeat packets before connecting

Unable to init RAMTRON storage

Unable to init RAMTRON storage
I tried to load an older version (Pixhawk1 - 4.0) but I still do not connect with a different message :
La séquence ne contient aucun élément.

à System.Linq.Enumerable.Aggregate[TSource](IEnumerable1 source, Func3 func)
à MissionPlanner.MAVLinkInterface.OpenBg(IProgressReporterDialogue PRsender, Boolean getparams) dans C:\Users\mich1\Desktop\CubePilot\MissionPlanner\ExtLibs\ArduPilot\Mavlink\MAVLinkInterface.cs:ligne 960
à MissionPlanner.Controls.ProgressReporterDialogue.RunBackgroundOperation(Object o) dans C:\Users\mich1\Desktop\CubePilot\MissionPlanner\ExtLibs\Controls\ProgressReporterDialogue.cs:ligne 111
I am sure it is a chinese clone, because of the printing on the box, the form of the big arrow is typical. It is mentioned : Pixhawk Pro and on the side : PX4
We have verified : the RAMTRON chip is present on the card.
Is it possible to find somewhere the right firmware for this device ?