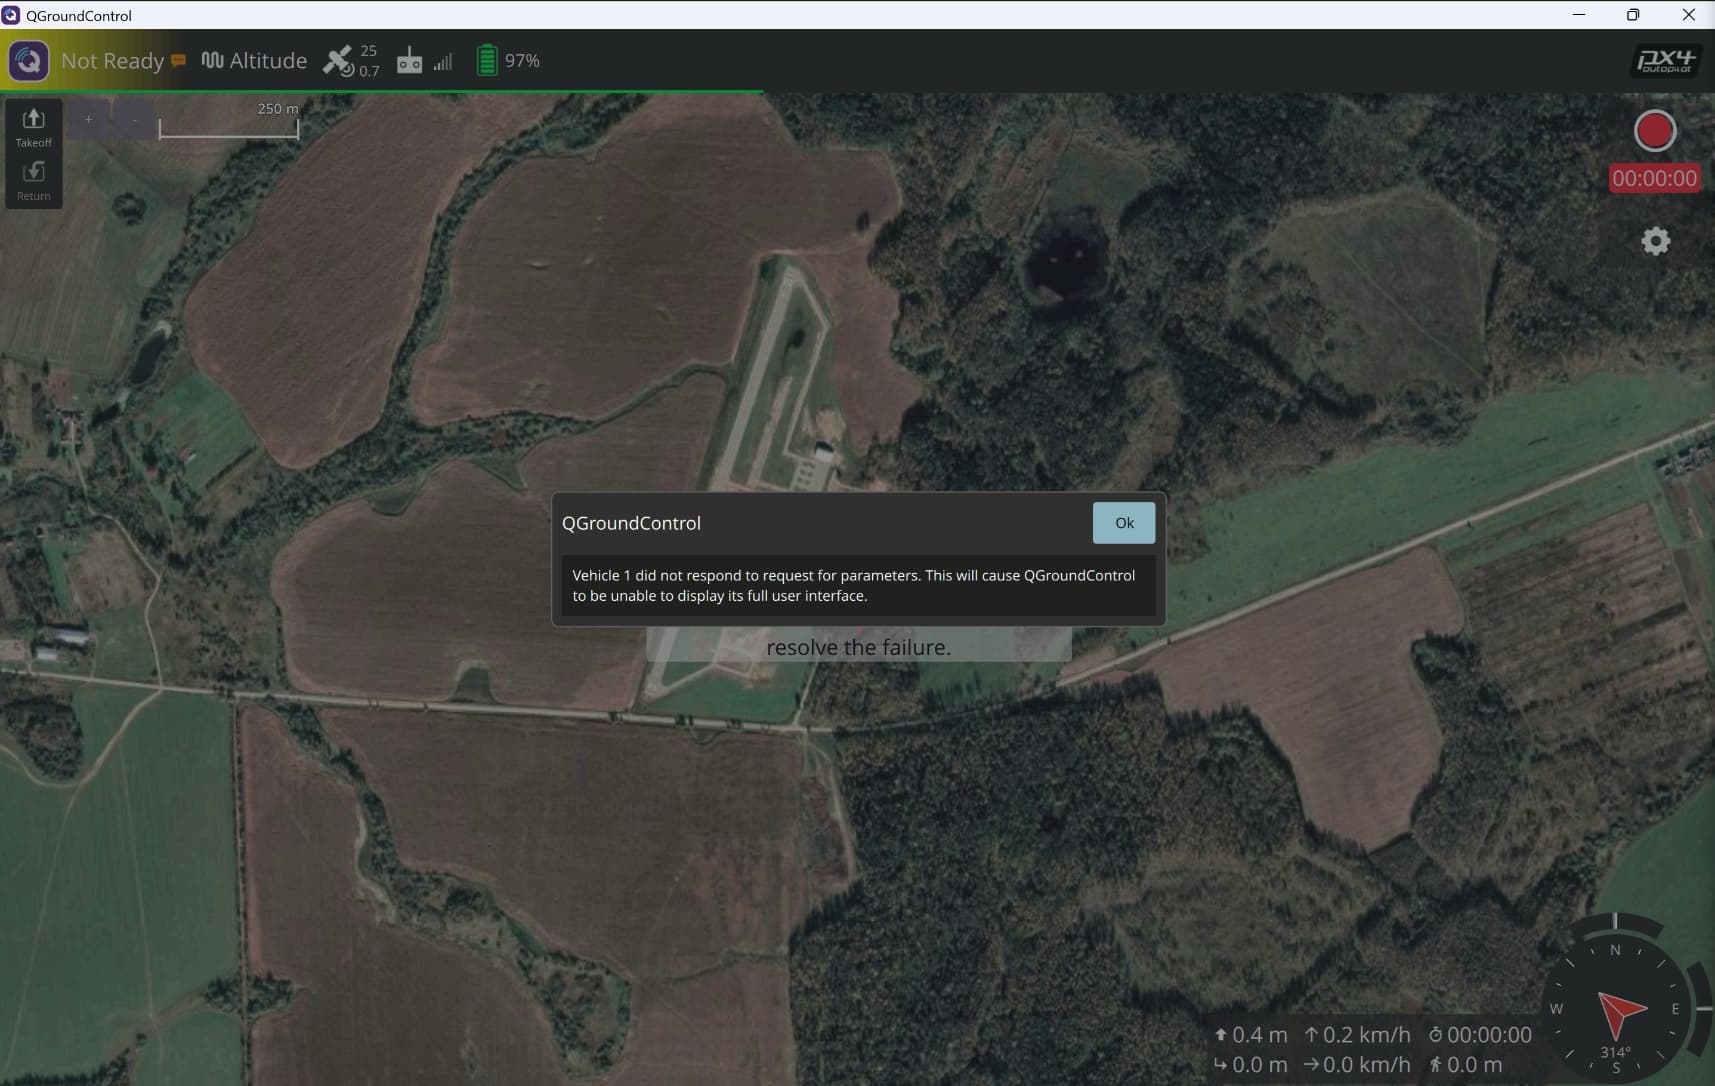
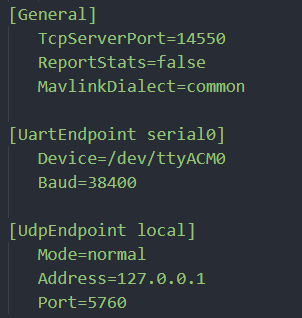
I’m using PX4 v1.16 Stable on a Pixhawk 6C flight controller and connecting QGroundControl (latest stable) through MAVLink Router.
My setup used to work perfectly, but recently QGC gets stuck on “Loading Parameters” and never finishes.
The issue occurs because the TELEM1 port is connected to the MK15 receiver via UART, while at the same time the USB port is connected to a Raspberry Pi running mavlink-router. It seems that this setup causes interference between the two MAVLink links.
Could you please advise how I can configure the system so that both connections can work simultaneously with MAVLink without conflicts? Also, which parameters should I set in the flight controller to achieve this?