

Hello! How to get the location of the drone when it was just connected? I used the position() function but it didn’t work.
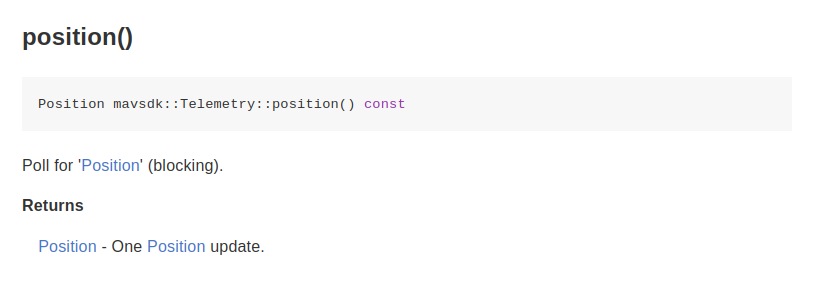
Please share the full output of what you saw.
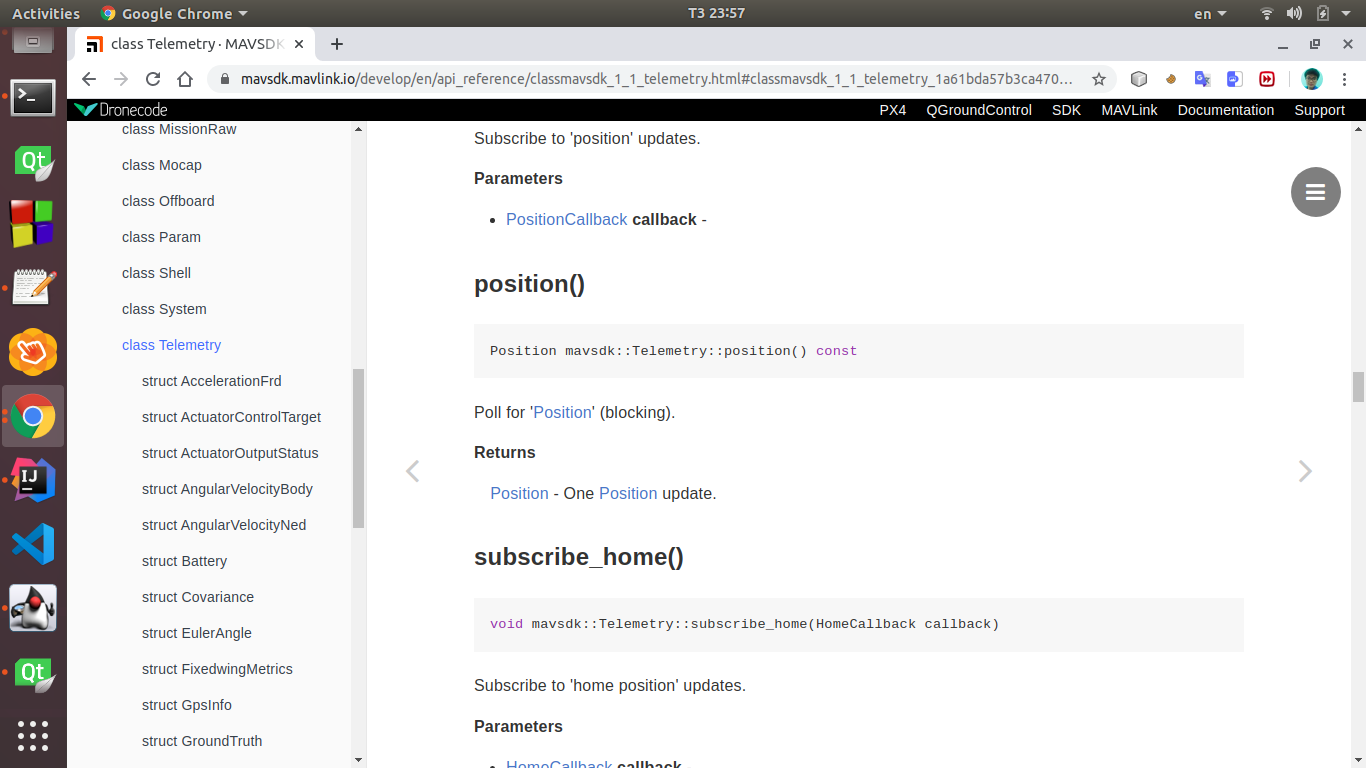
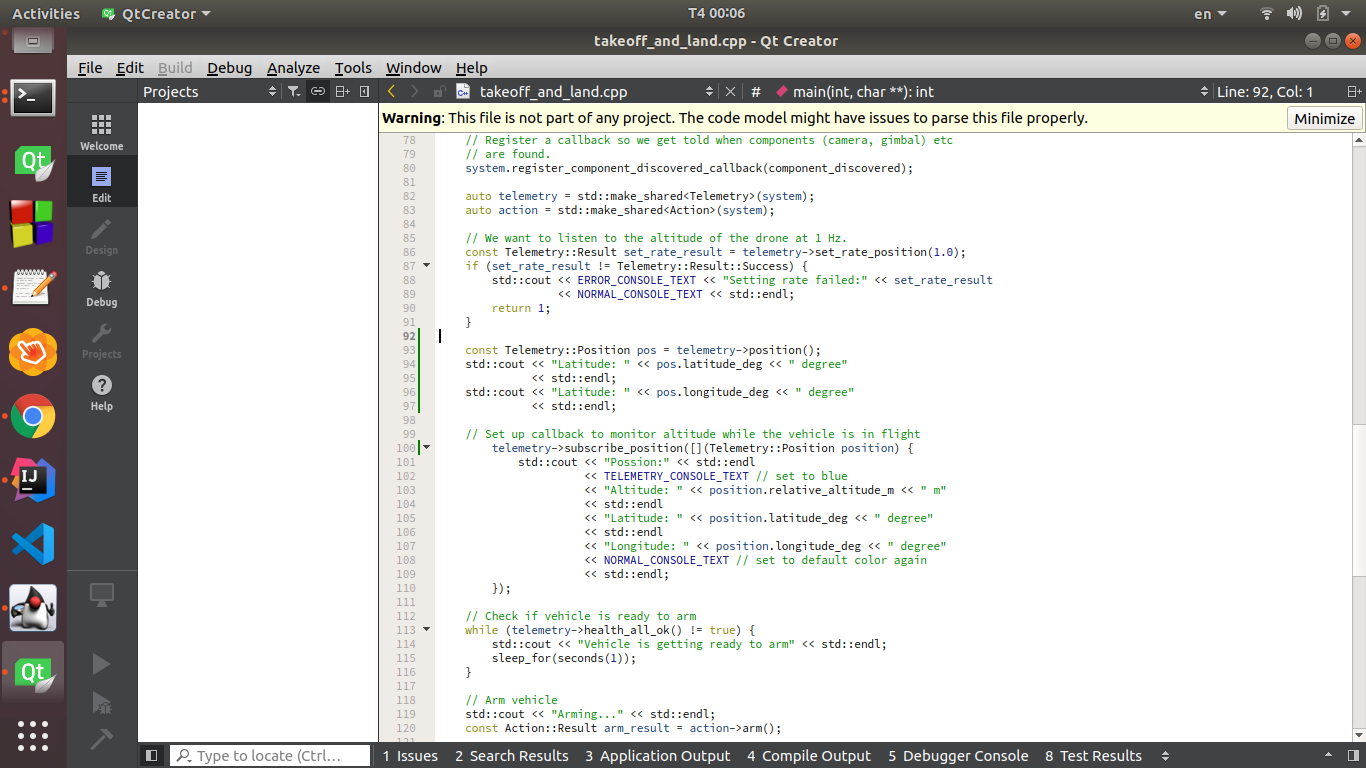
Looks correct. And what’s the output?
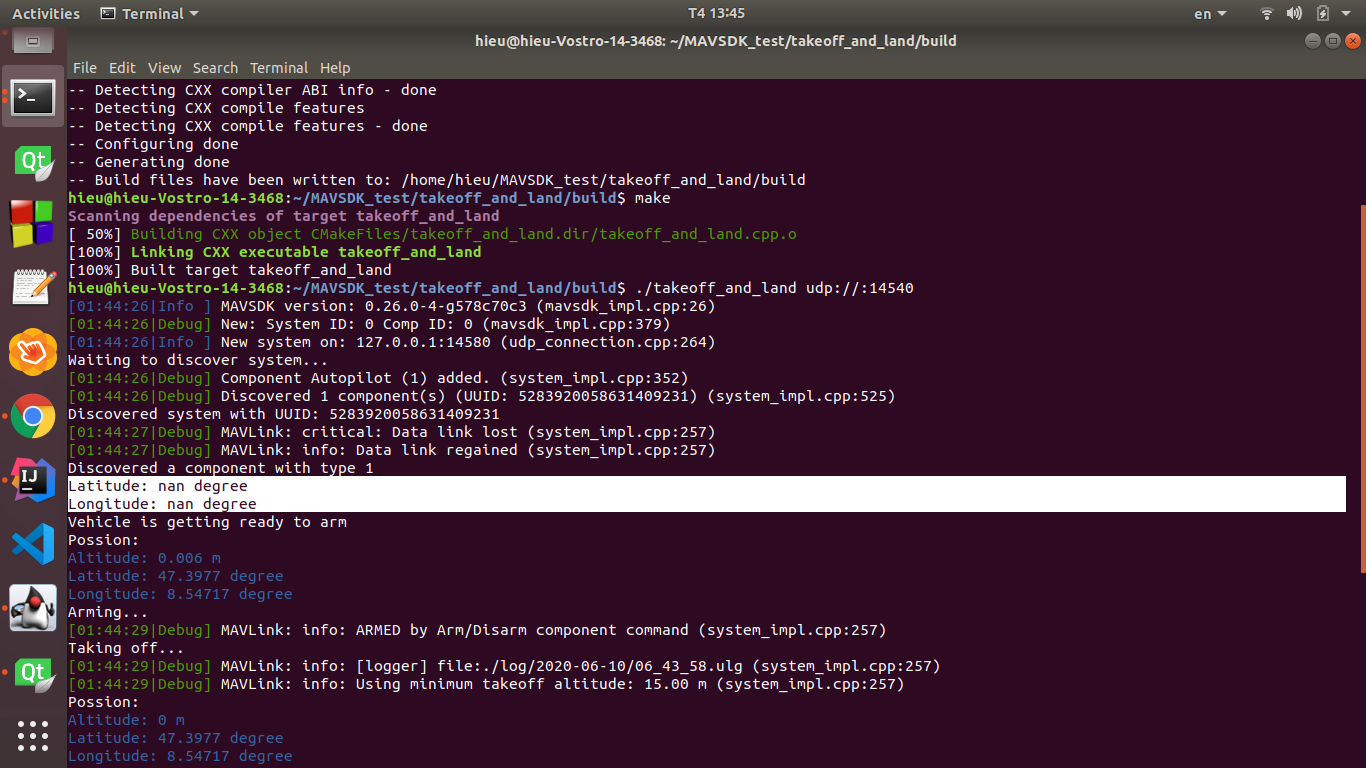
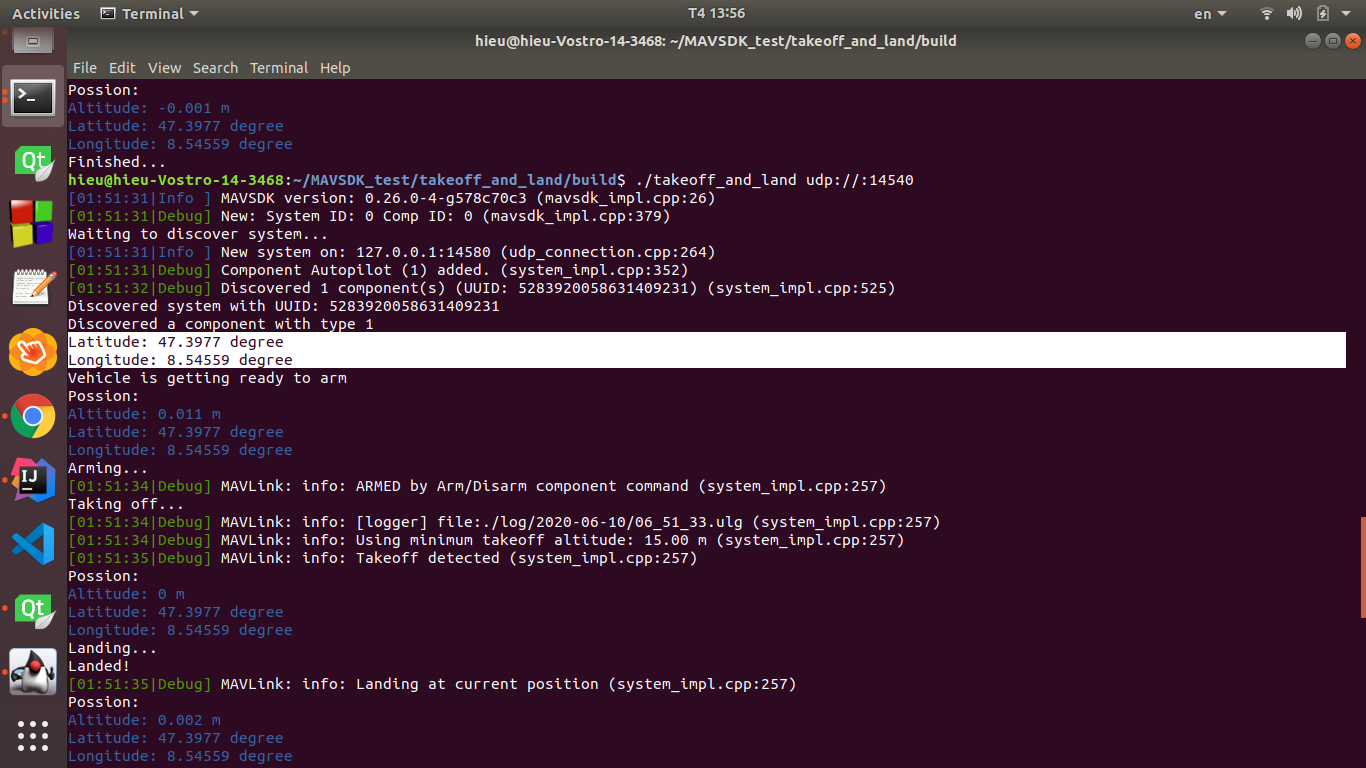
In the very beginning it has not received any position updates yet, so the data is still nan (not a number). Once it has received data it shows it.
If you did telemetry->position() later it should work.
Thank you! I will use it carefully.