

Hey guys, I’m the developer of ArduDeck, an open-source ground control station. I’ve recently added PX4 support and I wanted to ask for your help testing it. The app runs on any platform (Mac, Windows, Linux), and if testing goes well and the support stabilizes in the desktop app, I’ll bring it to the mobile app as well (Android and iOS).
Honest status first: the PX4 support is experimental. The full flow works against PX4 SITL, but it has not seen real PX4 hardware yet, which is exactly why I’m here.
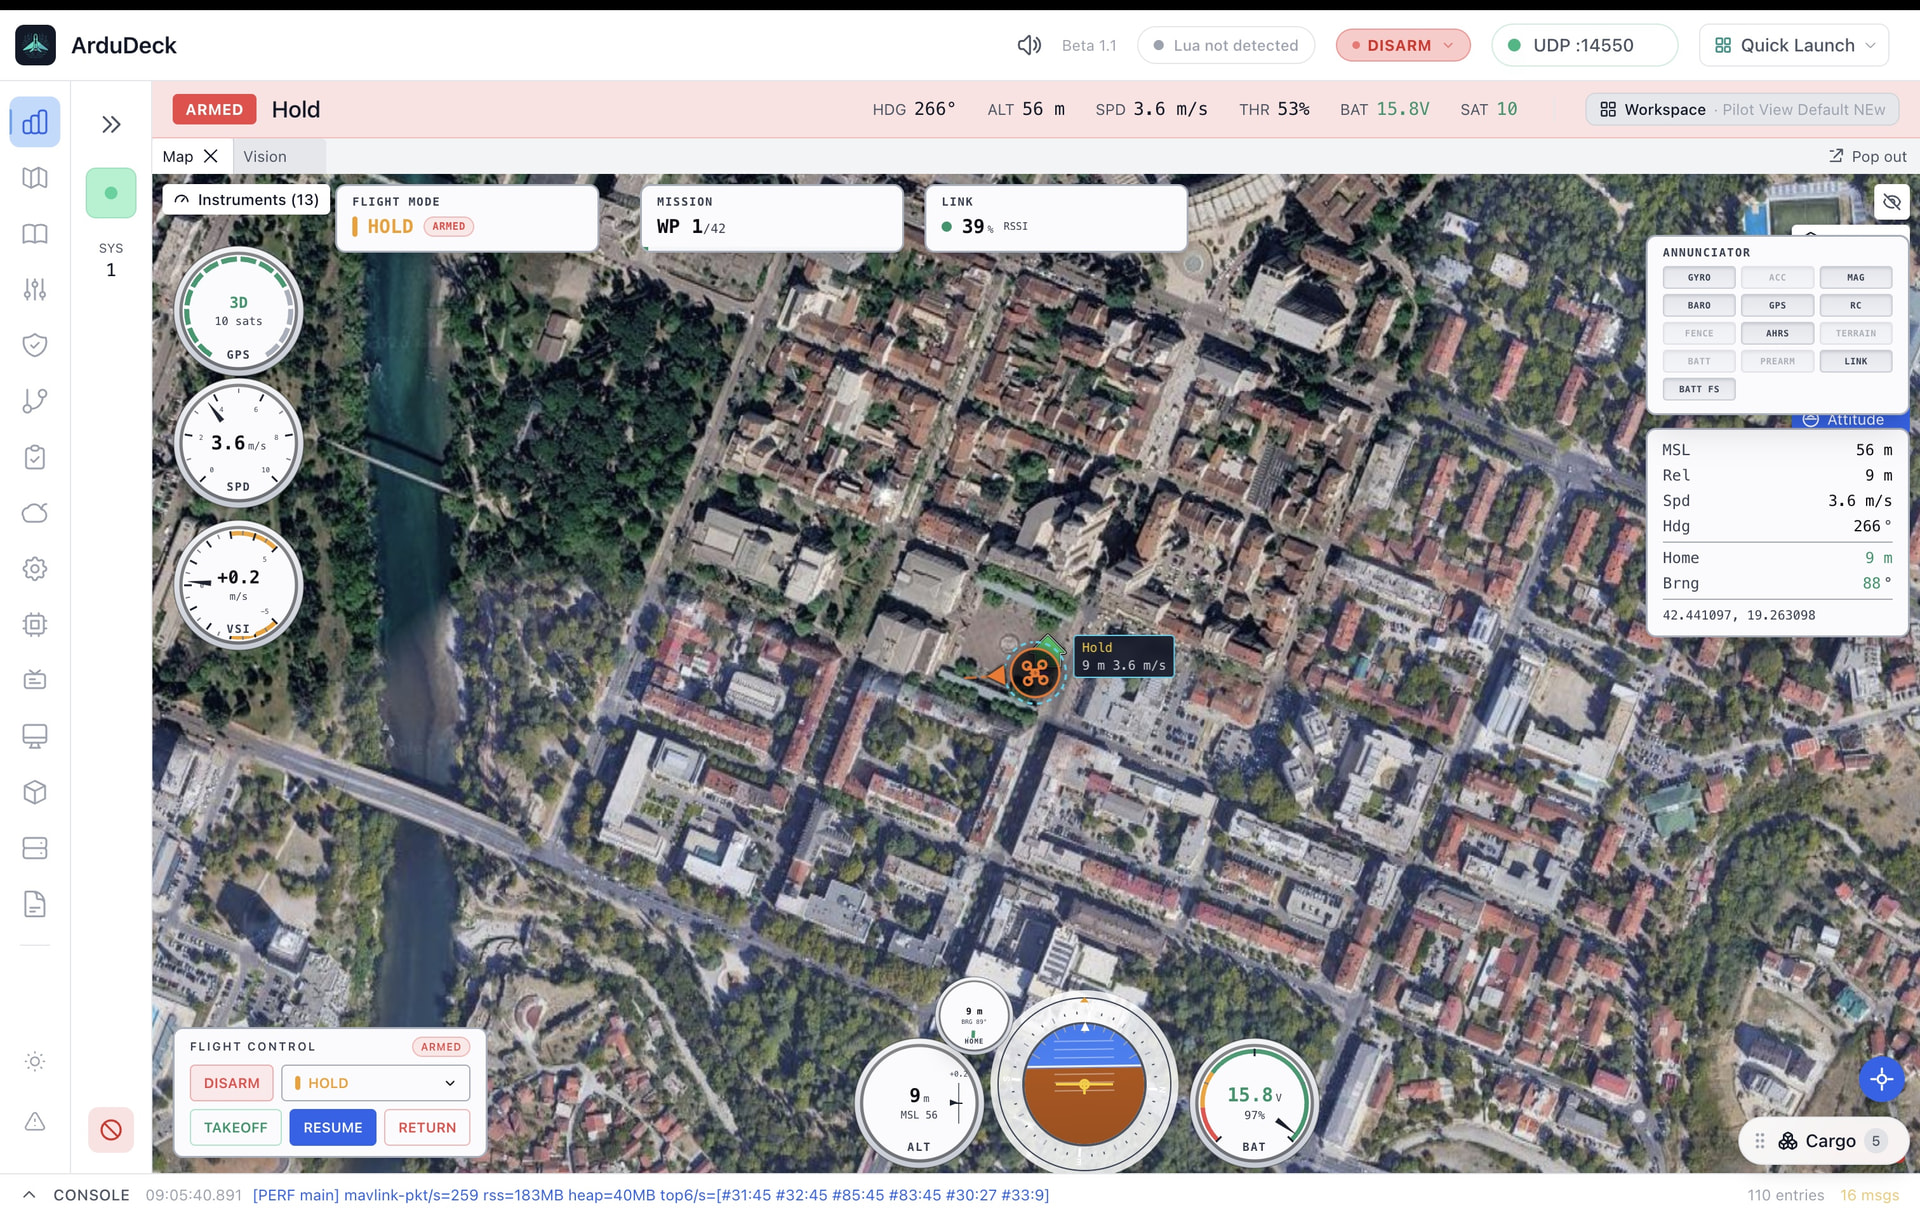
Here is a PX4 quad flying a mission in it, with the instruments docked on the map:
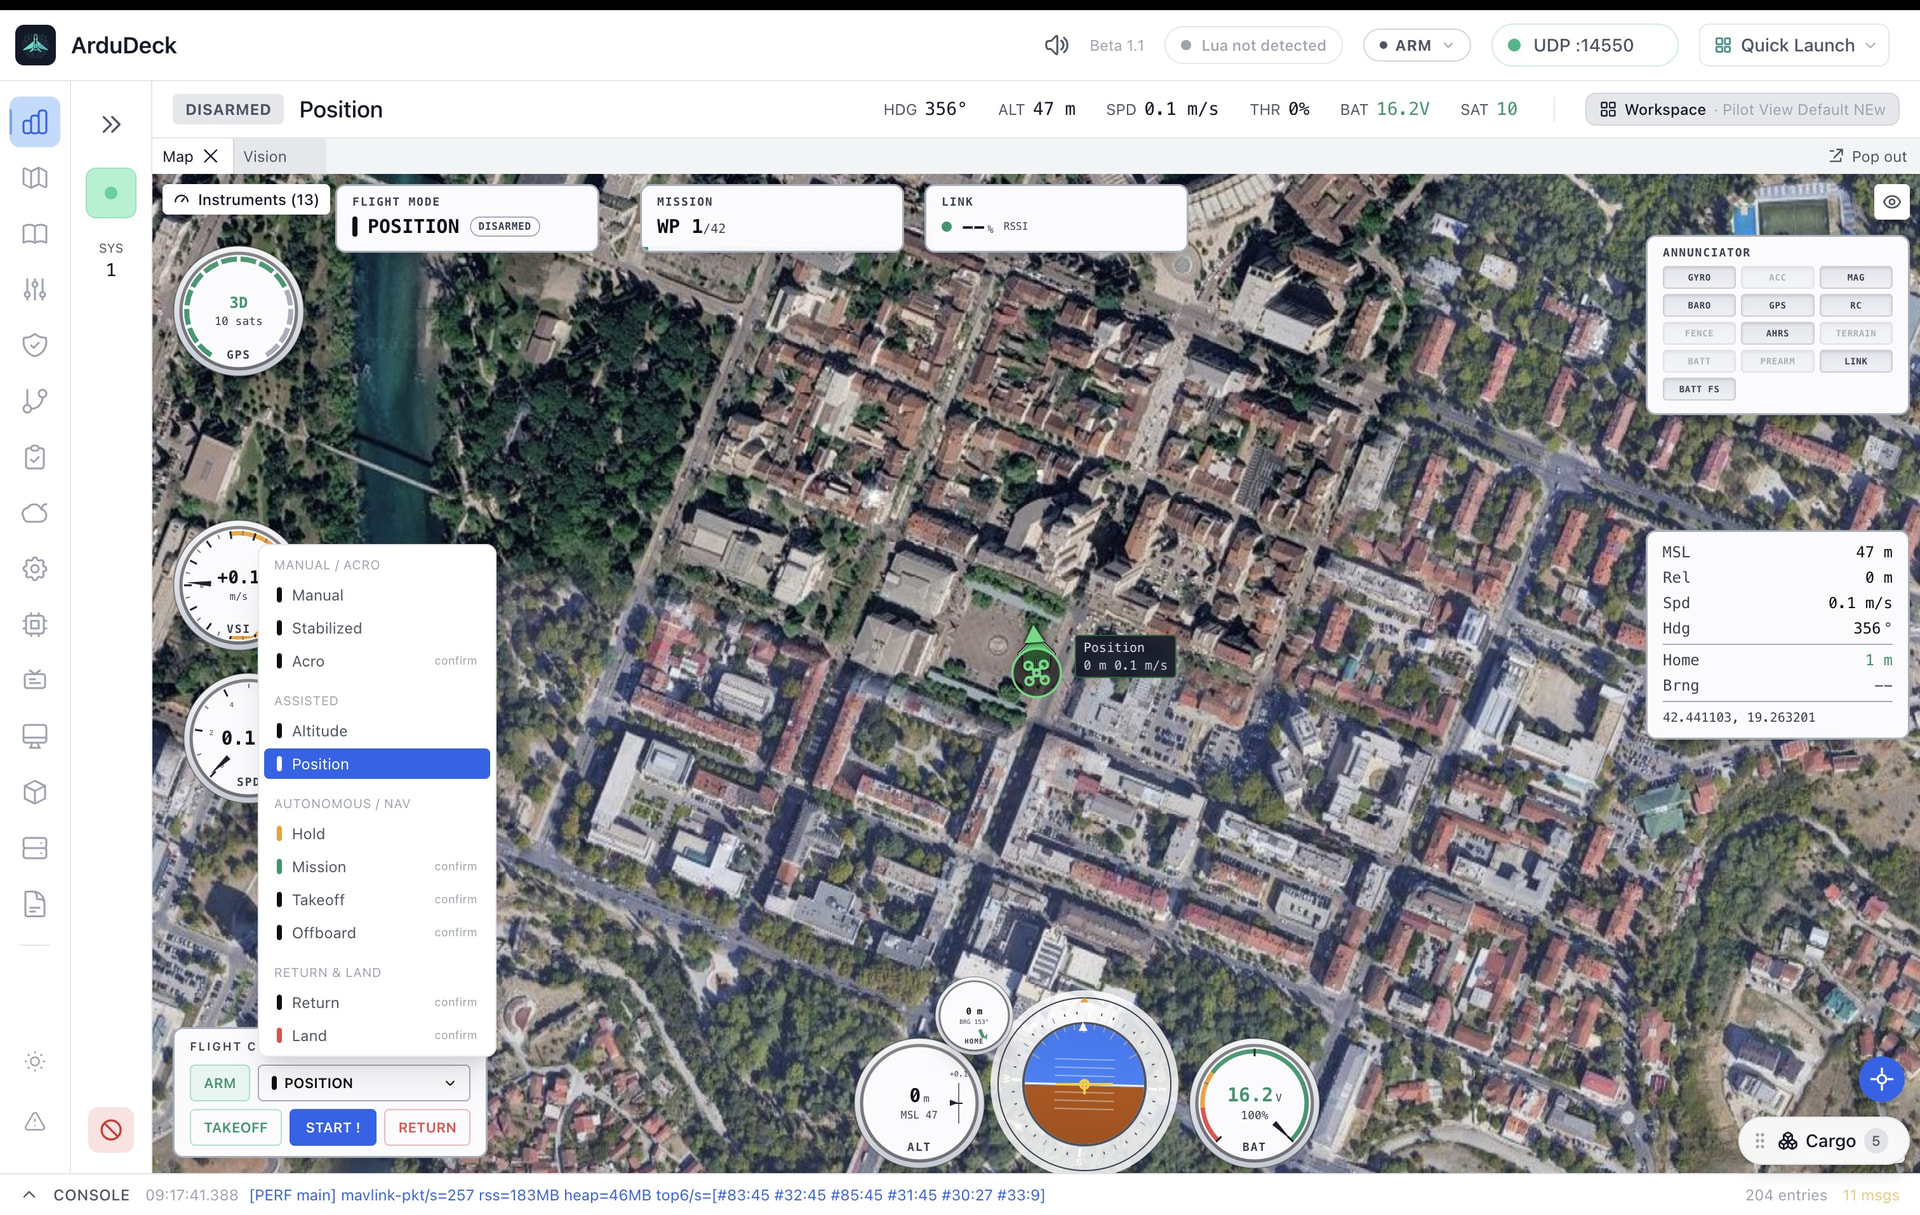
The flight modes are PX4’s own vocabulary, not translated ArduPilot ones:
What’s in it today:
- Automatic PX4 detection: PX4 flight modes decoded and commandable in PX4’s own vocabulary (Position, Hold, Mission, Offboard, and the rest, no translated ArduPilot names), prearm and preflight failures translated into plain hints
- Configuration: airframe picker, actuator outputs with motor test, RC and flight-mode slots, battery, safety and failsafes, backed by bundled PX4 parameter metadata with correct parameter typing
- PID tuning schemes for multicopter and fixed wing
- ULog: a native parser feeding the log explorer, health checks, and a map flight trace, with the log format detected automatically
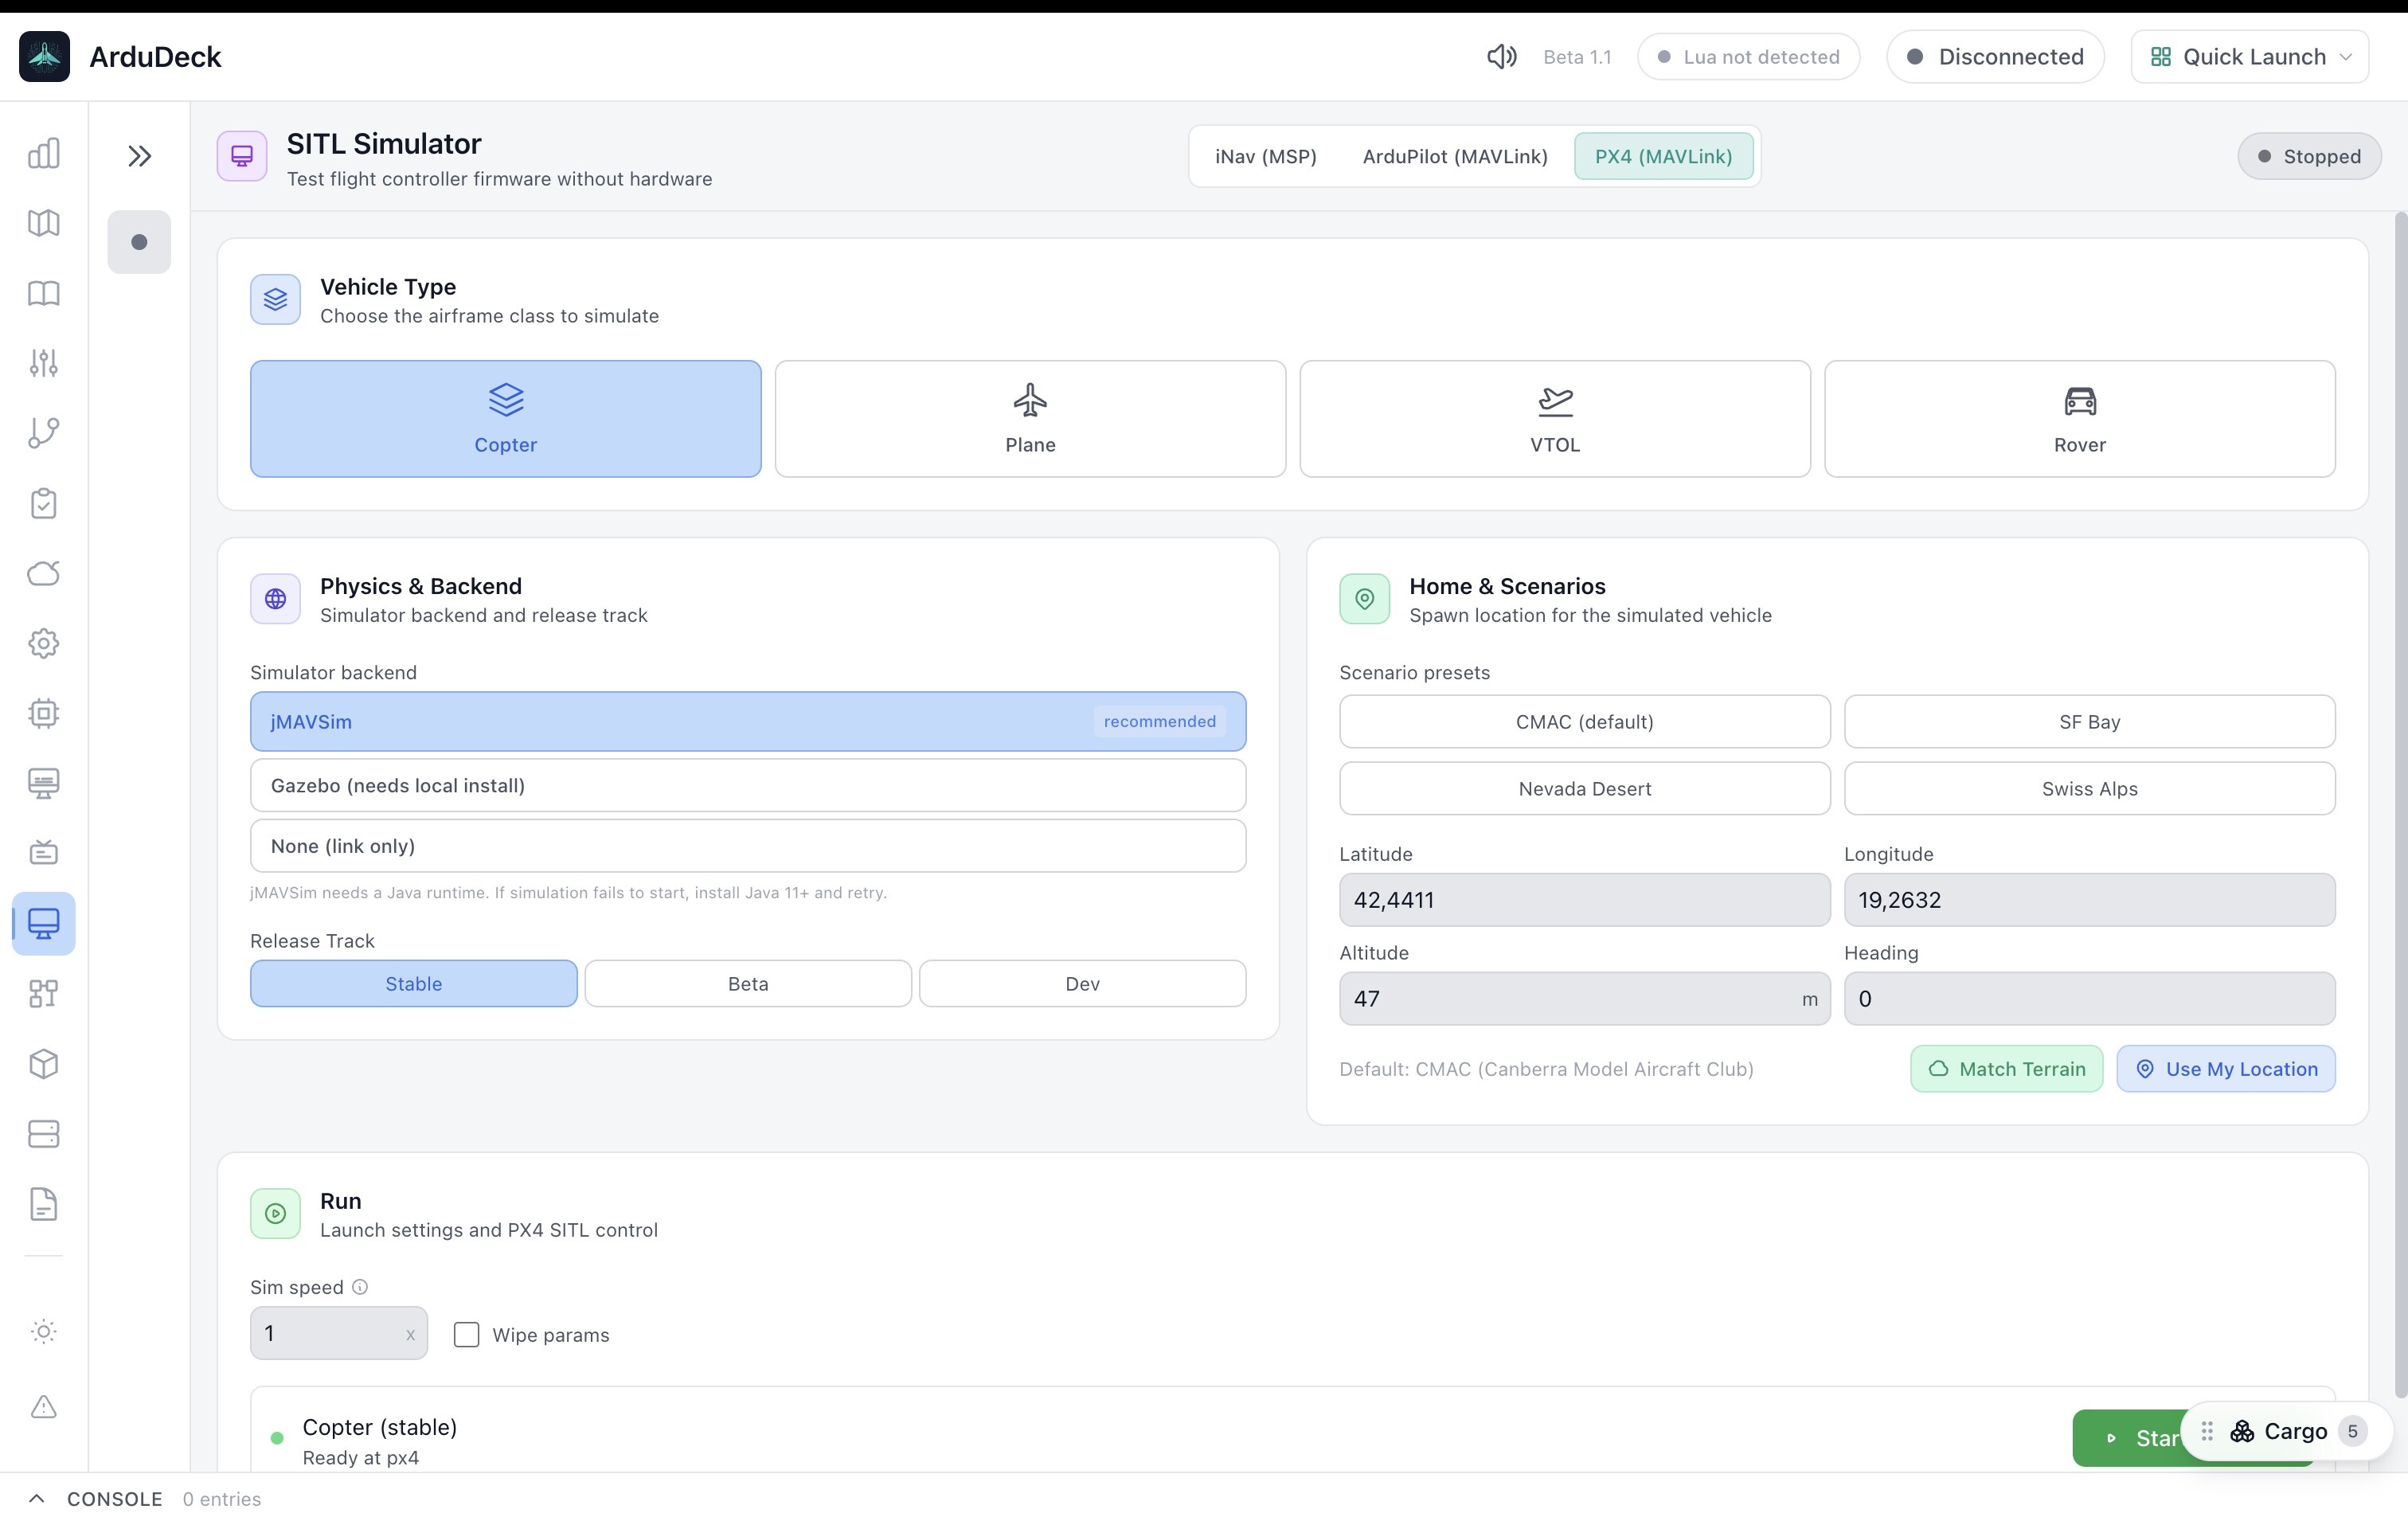
- In-app PX4 SITL using the built-in SIH simulator, so you can try all of the above without hardware in about two minutes
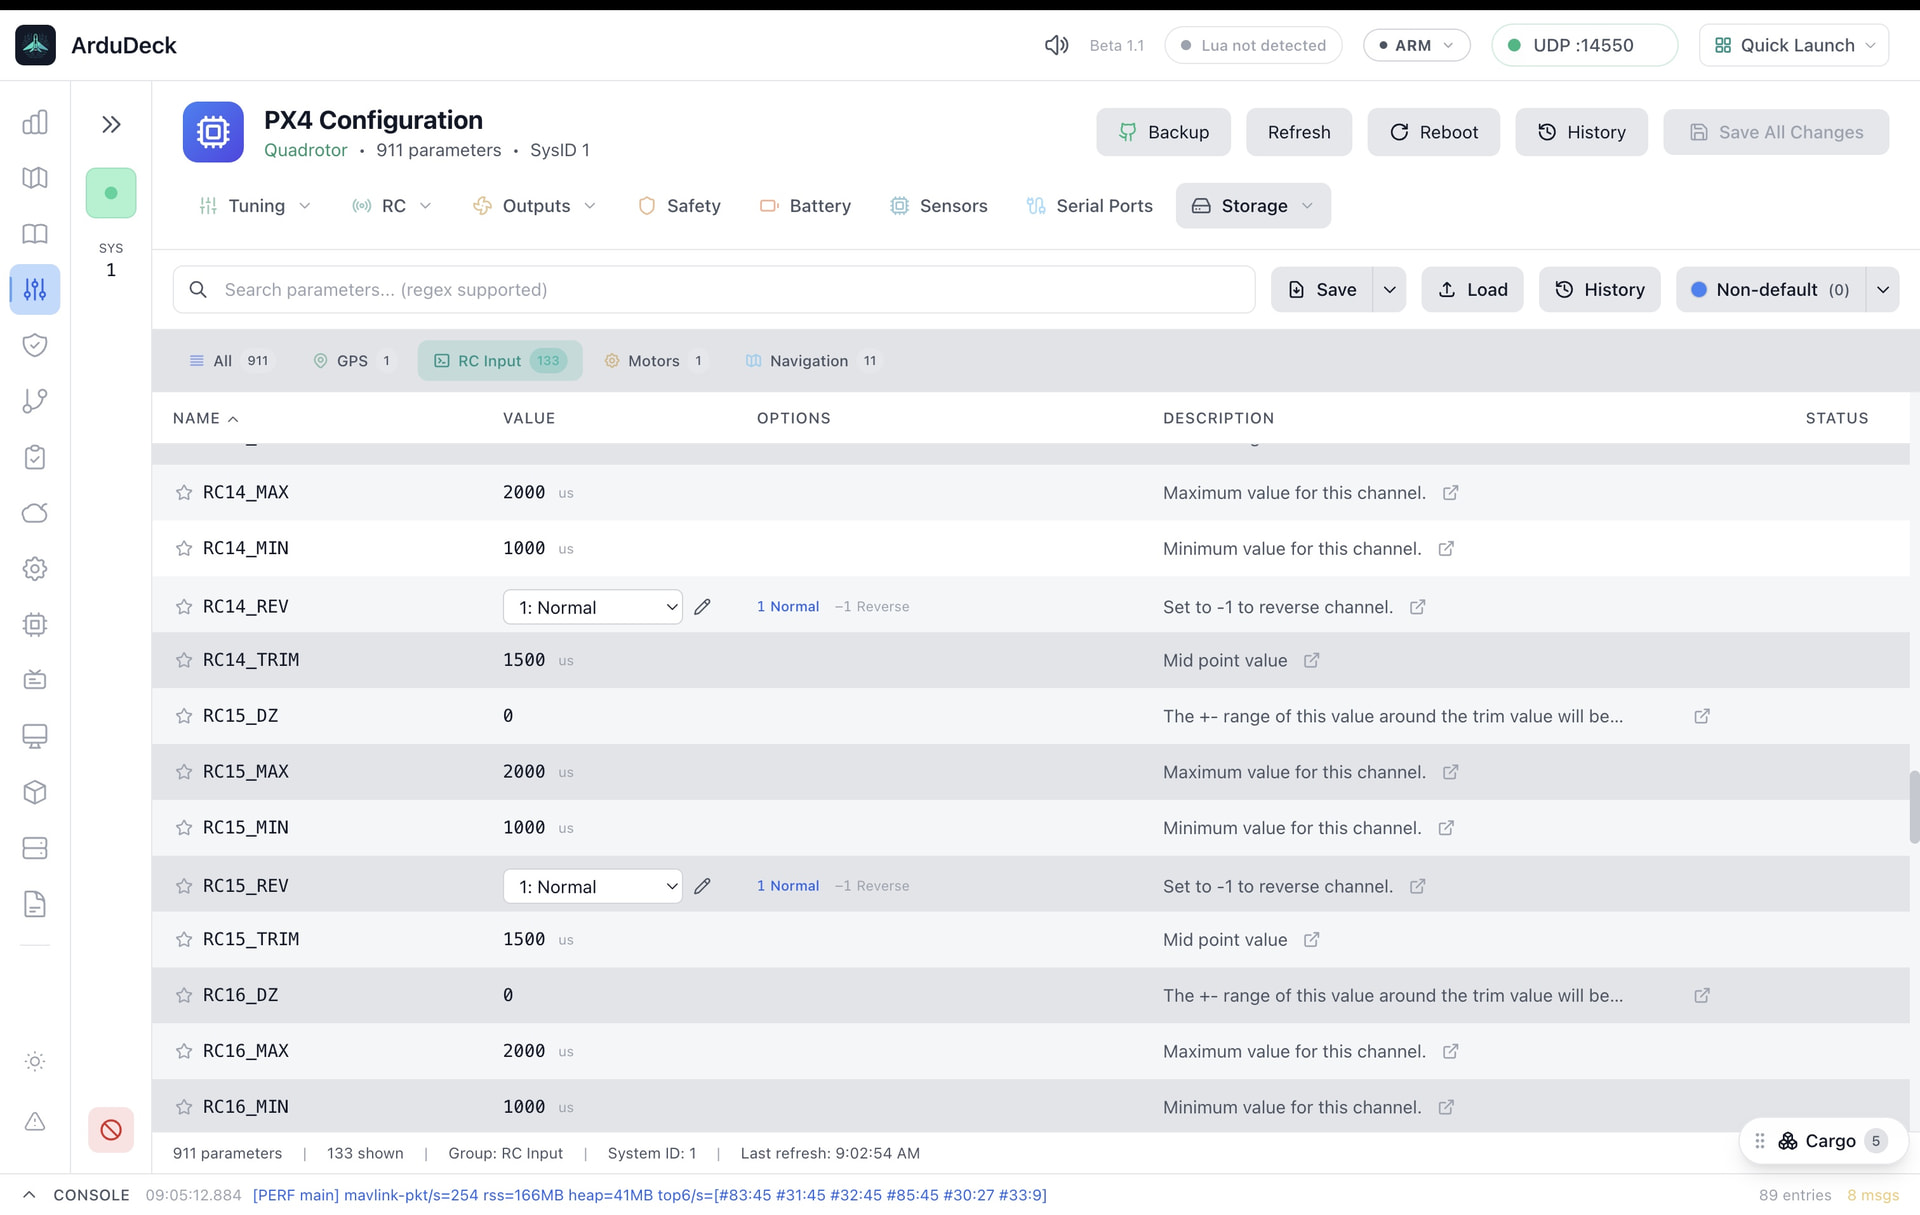
Parameters come with PX4 metadata, typed correctly (int vs float), searchable with regex:
And the built-in PX4 SITL launcher, so testing needs no hardware at all:
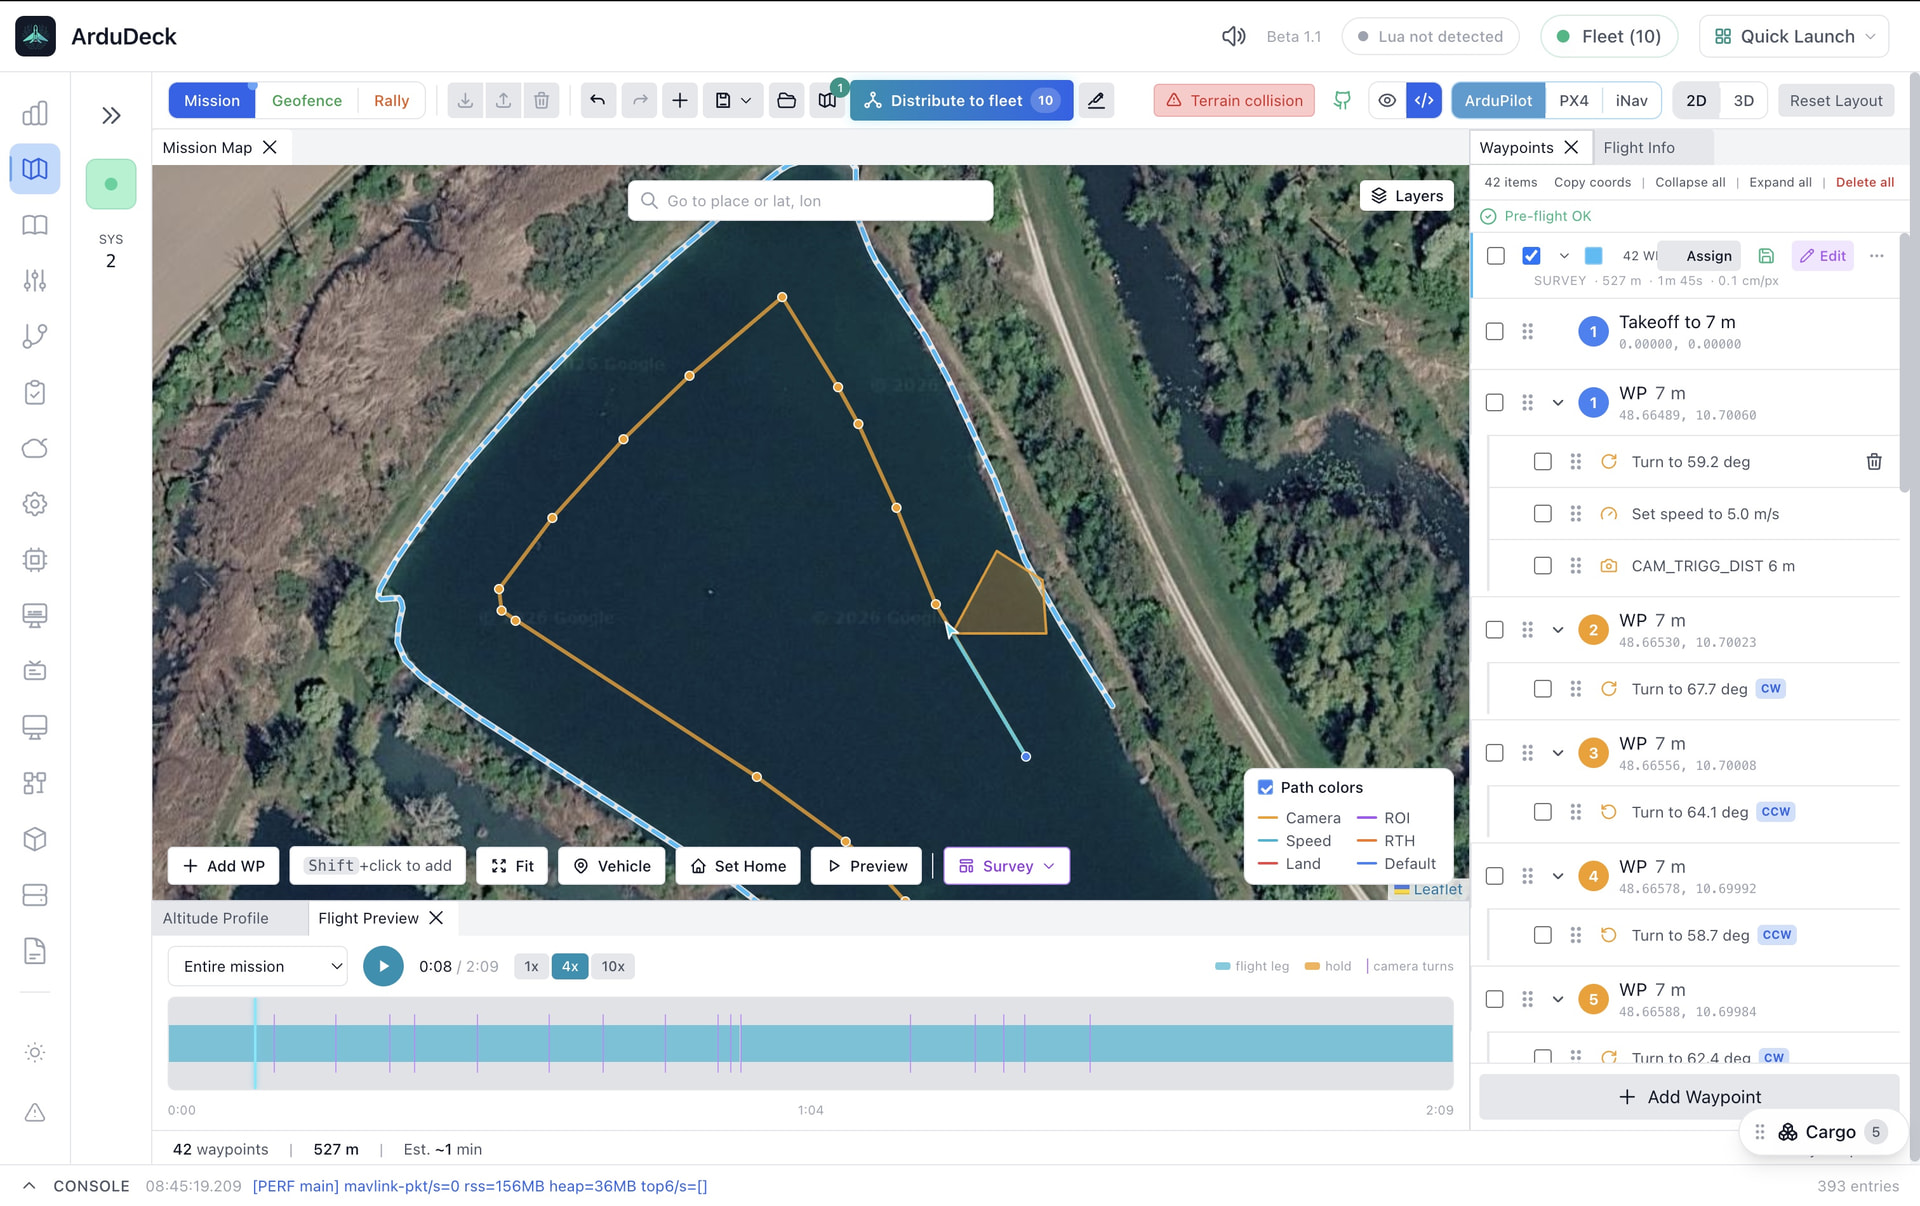
Since this is probably the first time most of you see ArduDeck, a quick word on the rest of the app, all of it works with PX4 connected. The telemetry screen is built around the map with the instruments docked directly on it (that is the first screenshot above), there is a catalog of instruments with live previews, multi-vehicle flying, and a HUD widget for EdgeTX radios built visually in the app. And missions can be previewed before upload: a gizmo flies the plan on the map with a live camera cone, on a scrubbable timeline:
What would help me most:
- Connect a real PX4 vehicle (USB or telemetry) and tell me what breaks: wrong parameter values, modes that refuse to switch, anything that looks off
- Run through the config tabs against QGC side by side and flag any disagreement
- Open a ULog from a real flight and check the analysis against what you know happened
More about the app: ArduDeck Beta 1.1: The Map Is the Cockpit - ArduDeck Blog
Download: Releases · rubenCodeforges/ardudeck · GitHub
Issues and reports: Issues · rubenCodeforges/ardudeck · GitHub
I’ll be in this thread. Thanks for any time you throw at it.
