

Hi everyone,
I’m Viacheslav (Slavkó), a software engineer and UAV systems developer based in Portugal. I’m looking for contract or part-time work, primarily remote, but I’m also open to travel and on-site integration/testing.
I have around 20 years of professional software engineering experience, mostly backend and distributed systems. In my last full-time role I was a backend engineer and tech lead, helping build and launch the MVP of a company that has since grown to a valuation of $10B+.
Over the last several years, my focus has shifted increasingly toward UAVs, robotics, computer vision, edge AI, and flight-system integration.
UAV / robotics
My main aircraft focus is fixed-wing UAVs, with 100+ hours of VLOS fixed-wing flight experience.
Hands-on experience includes:
- assembling, repairing, upgrading, configuring and tuning UAVs
- ArduPilot, INAV, MAVLink, Lua scripting
- Linux companion computers and low-cost SBCs
- onboard real-time software interacting with the flight controller
- camera capture, video recording and onboard processing
- telemetry, networking, mission planning, failsafes and log analysis
- Gazebo / SITL simulation
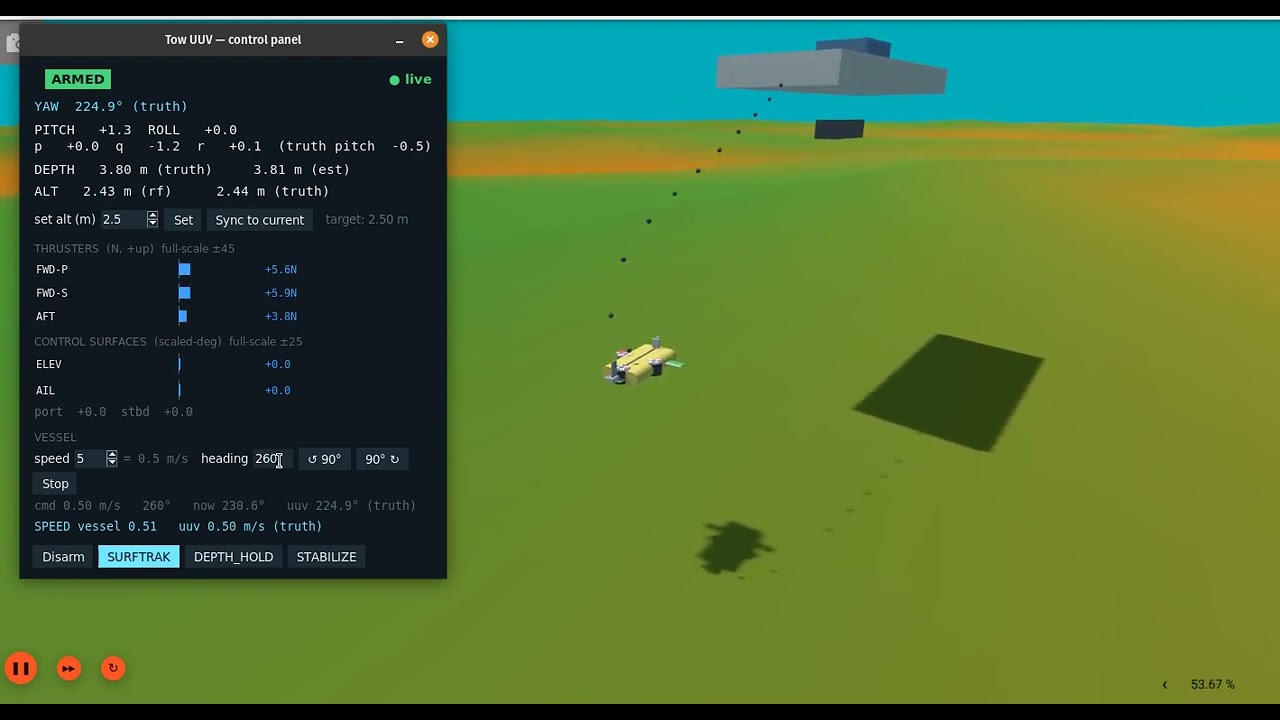
- some UUV / ArduSub simulation and integration work
- DJI API integration
A couple of years ago I had a contract to validate the DJI API for a customer use case. During that work I also found and reported an issue in DJI’s documentation.
DJI API validation repo:
https://github.com/medvedev/dji_cloud_api_test_app
A typical area I enjoy is the full integration chain:
flight controller → MAVLink → companion computer → cameras/perception → onboard processing → navigation/control → ground software
I’ve also made small contributions/fixes to QGroundControl and ArduPilot.
I do practical hardware work myself, including repairs, rewiring, upgrades and component integration. For projects that need more prototyping capacity, I also have a trusted peer I can bring in with experience in 3D printing, microcontrollers and rapid prototyping.
Computer vision / Edge AI
I’ve worked on:
- AI target tracking
- onboard CV
- inference on low-cost, low-power hardware
- visual navigation in GNSS-denied environments
- PyTorch / TensorFlow / OpenCV pipelines
My ML/DL training includes XCS330 – Deep Multi-Task and Meta Learning from Stanford Online, Fundamentals of Deep Learning from NVIDIA, Deep Reinforcement Learning from Hugging Face, and a Machine Learning certificate from Coursera.
Regulation / field testing
I hold EU A1/A2/A3 remote-pilot qualifications and recently prepared and submitted a PDRA-based Specific-category application in Portugal for BVLOS fixed-wing operations.
I also have access to locations in Portugal where suitable UAVs can be legally tested under the A3 Open category, so I can take projects beyond simulation and bench testing into real flight testing.
I was also a speaker at the Portugal Defense Startups Meetup, on how EU regulatory constraints can slow down defense innovation.
I also have direct exposure to the Ukrainian UAV / defense-tech ecosystem, including the Victory Drones and BRAVE1 communities.
What I’m looking for
I’m especially interested in projects involving:
- fixed-wing UAV integration
- ArduPilot / MAVLink
- companion computers and onboard Linux
- UAV simulation
- computer vision / Edge AI
- GNSS-denied navigation
- DJI API
- telemetry / networking
- flight testing and debugging
- prototypes where software needs to work with real hardware
I’m strongest on the software and systems-integration side, but I’m comfortable across a large part of the UAV stack, what I sometimes describe as full-stack UAV development.
Profiles
LinkedIn:
https://pt.linkedin.com/in/smedvedev
Upwork profile | Toptal profile | Stackoverflow
Videos / demos
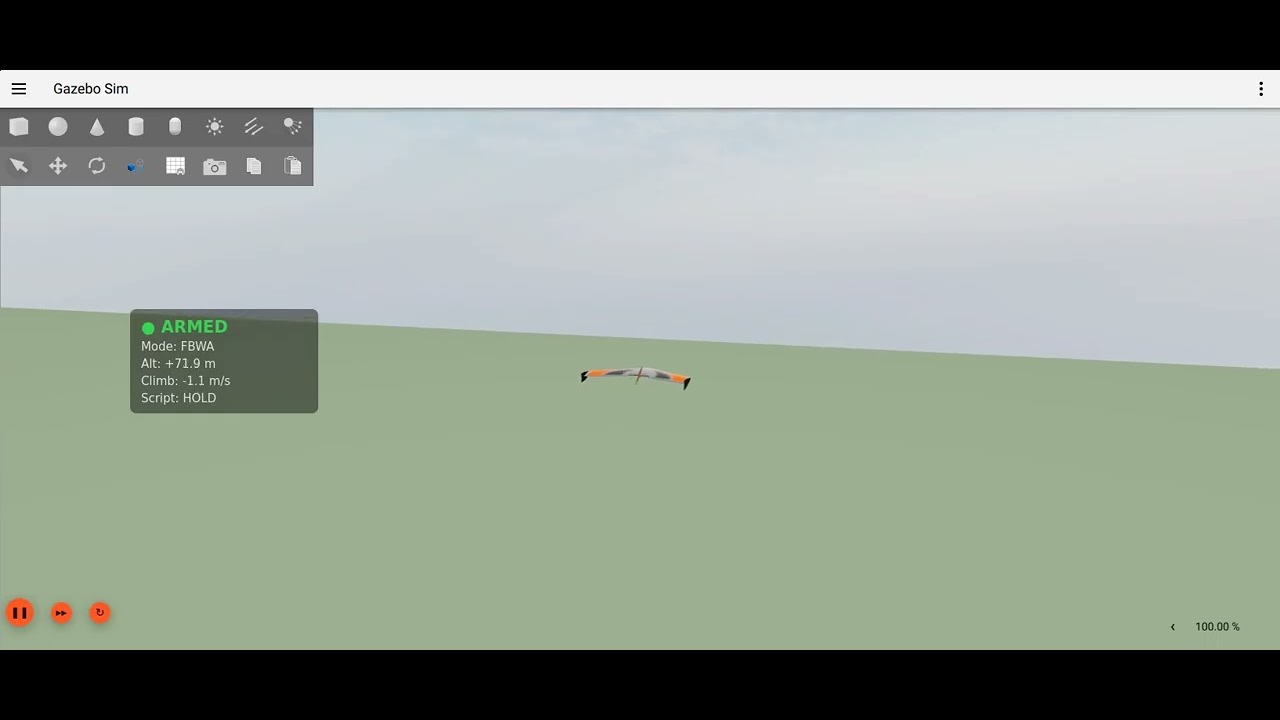
No-GPS catapult takeoff (Ardupilot, Lua)
Towed UUV simulation in Gazebo:
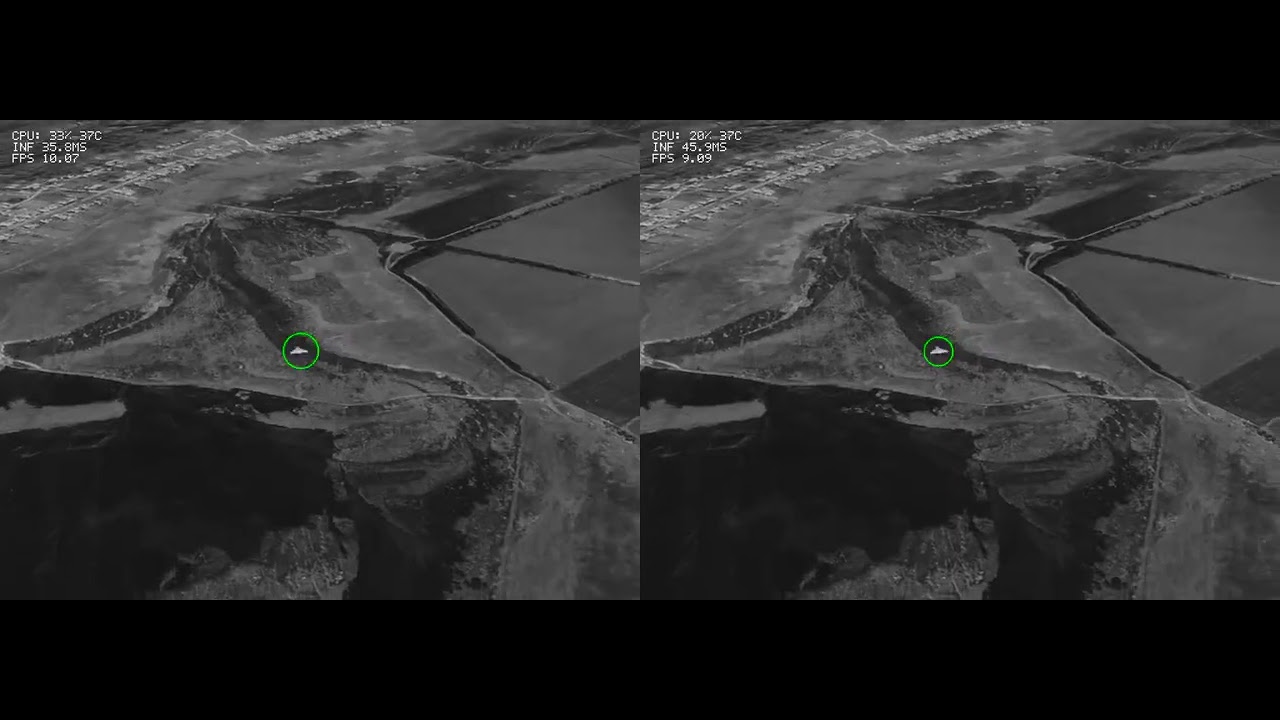
AI target-tracking PoC on a ~$10 computer:
Feel free to DM me if this sounds relevant to what you’re building.