Title: Real-Time Non-Linear Derivative Filter Engine for IMU Vibration Mitigation (Looking for Raw Flight Logs)
Hi everyone,
I am developing a non-linear software filtering engine designed to mitigate severe high-frequency structural noise spikes caused by 10,000+ RPM brushless motors on low-cost MEMS IMUs (like the MPU6050) without introducing traditional phase delay.
The Core Problem with Standard Approaches
Traditional low-pass or moving average filters smooth out structural noise but introduce a catastrophic phase delay (time lag). In aggressive flight loops, even minor delays lead to over-correction, control loop oscillations, or crashes.
The Proposed Innovation
A physical drone frame has structural inertia and cannot accelerate infinitely fast in a fraction of a millisecond. High-frequency electronic noise glitches and mechanical motor harmonics present mathematically impossible angular rate spikes.
Instead of slow time-averaging, this engine evaluates second-order discrete derivatives (Angular Jerk) in real-time at a 400 Hz sampling rate (dt = 0.0025s).
1. Discrete Time Derivative Calculation
Using a fixed 3-element sliding memory buffer [y_k, y_k-1, y_k-2] tracking raw sensor inputs across discrete time steps, we isolate instantaneous rate changes:
-
First Discrete Derivative (Velocity):
v_k = (y_k - y_k-1) / dt -
Second Discrete Derivative (Acceleration / Jerk Magnitude):
a_k = (v_k - v_k-1) / dt = (y_k - 2*y_k-1 + y_k-2) / (dt^2)
2. Dynamic Gaussian Trust Factor (W)
We evaluate the absolute acceleration magnitude |a_k| against a calibrated physical threshold (Theta). A non-linear Gaussian exponential decay function calculates a real-time trust weight W between 0.0 and 1.0:
W(a_k) = exp( -1 * (|a_k| / Theta)^2 )
- Normal Physical Flight (|a_k| << Theta): W approx 1.0 (100% trust raw data)
- Motor Vibration Spike (|a_k| >> Theta): W approx 0.0 (0% trust, reject noise spike)
3. Kinematic Trajectory Prediction & Convex Blend
When an intense vibrational spike occurs and trust drops (W → 0), the engine bypasses the raw sensor reading and predicts the orientation state (y_hat_k) using a 1st-order localized Taylor polynomial expansion from the previous safe state (y_bar_k-1):
y_hat_k = y_bar_k-1 + (v_k-1 * dt)
To protect against integration drift during continuous high-RPM vibrations, a frame counter forces an incremental fallback to raw tracking if W stays at zero for more than 4 consecutive frames.
The final clean output (y_bar_k) is compiled using a smooth convex combination blend of the measured and predicted states:
Filtered Output: y_bar_k = [ W(a_k) * y_k ] + [ (1.0 - W(a_k)) * y_hat_k ]
Current Status & Looking for Real Raw Flight Data
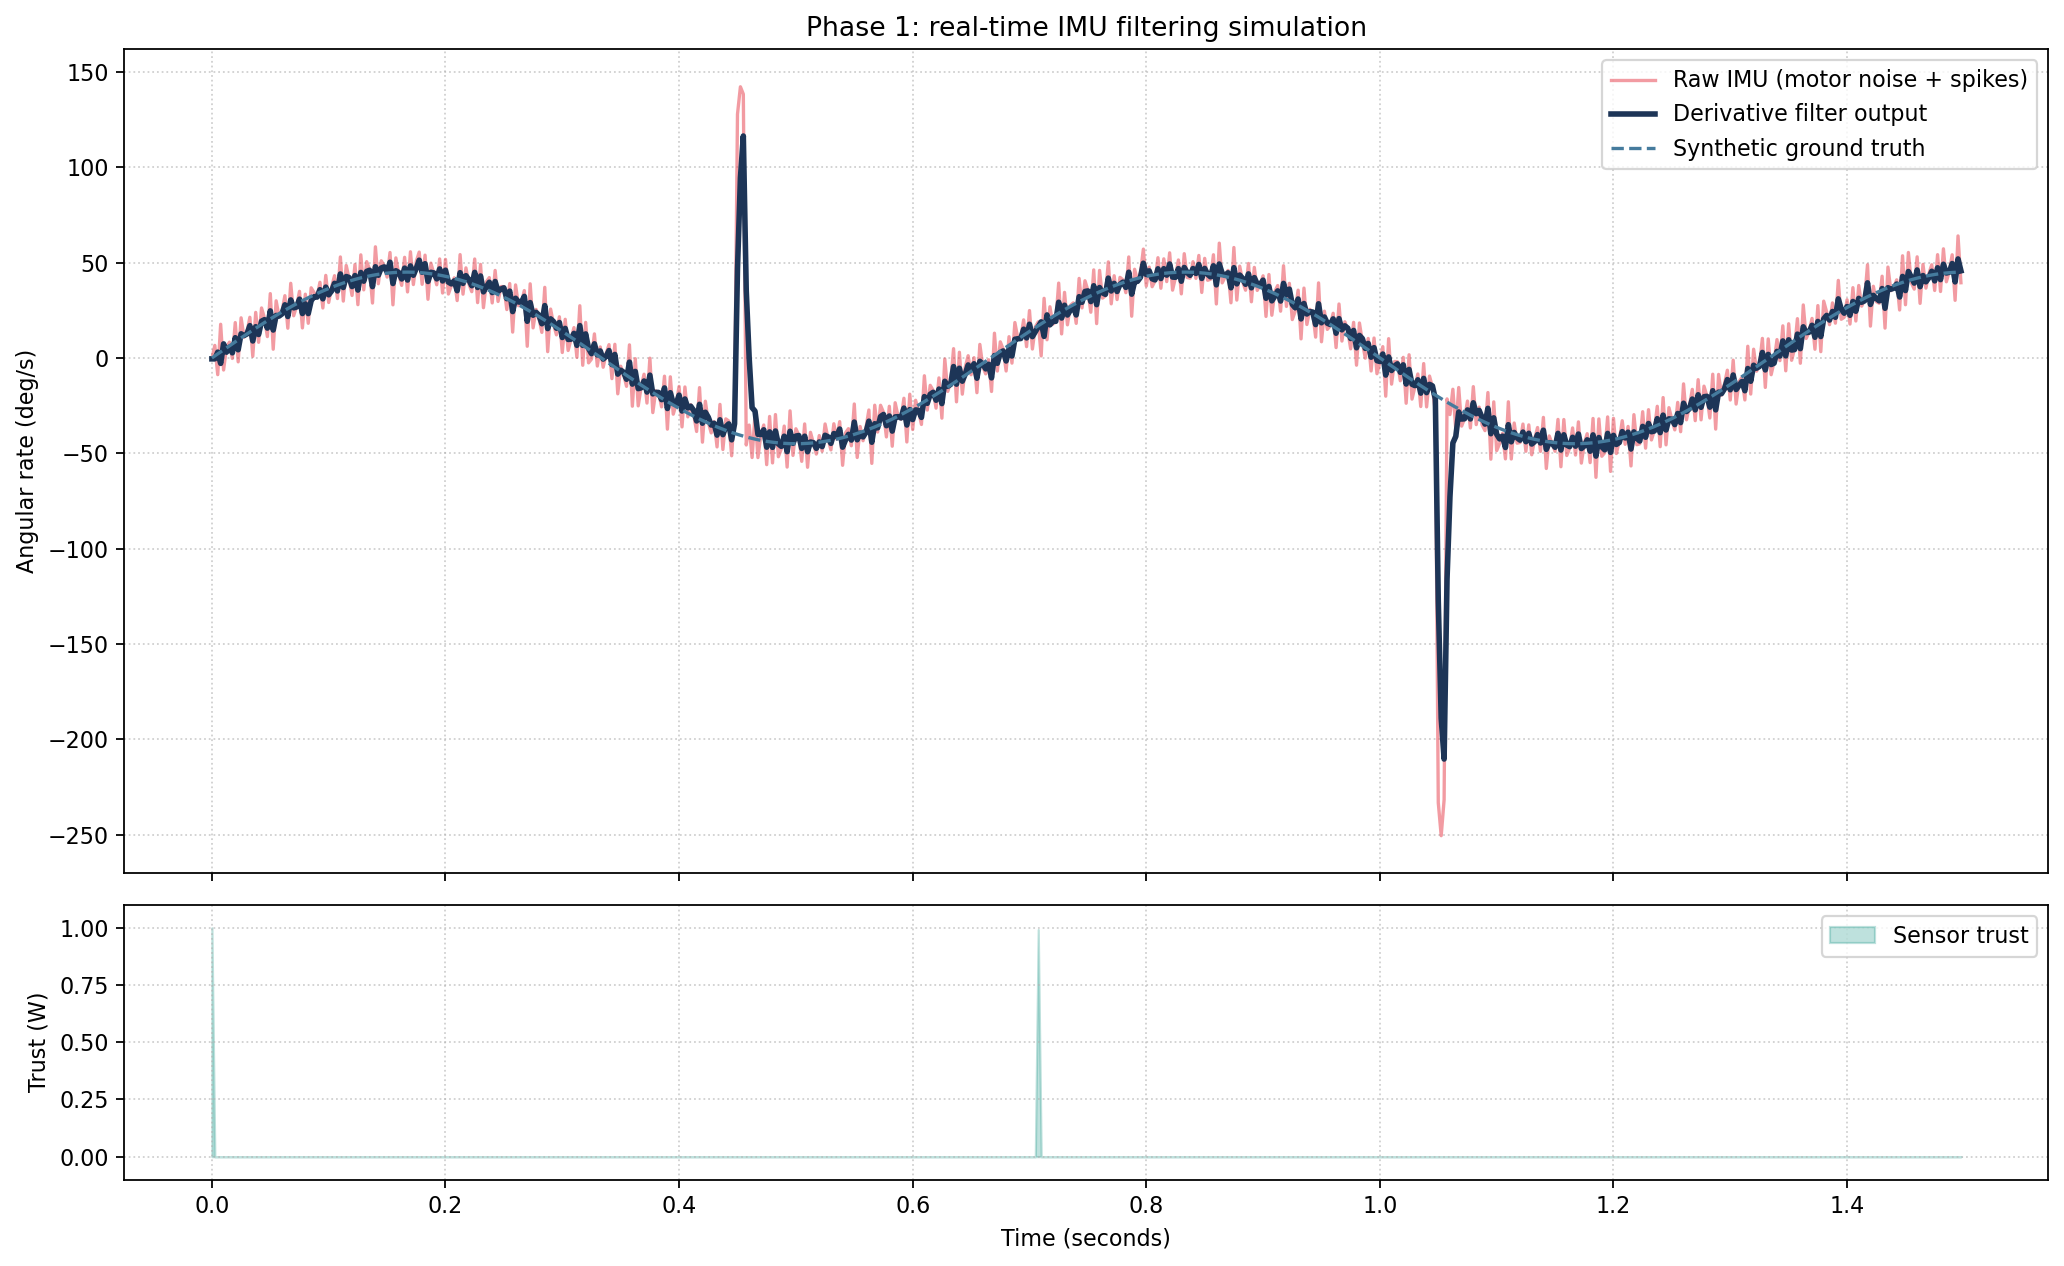
I have successfully built a zero-cost Python sensor simulation workbench to stress-test this math model against synthetic 10,000+ RPM motor noise and random clipping spikes, showing great results with zero phase lag. I’ve also completed a bare-metal #![no_std] Rust implementation of the processing engine intended for 32-bit dual-core architectures like the ESP32.
However, I do not have access to a physical drone right now to generate real operational test data and benchmark the engine further.
Could anyone in the community share raw, unfiltered high-rate IMU flight data (preferably CSV, bin, or log format)? I am specifically looking for files that contain raw gyroscope streams heavily contaminated by real motor vibrations or high-frequency structural harmonics. I want to pass your real-world messy data through my engine to verify if the threshold limits hold up perfectly.
I would also love to get the community’s thoughts on:
- Edge cases regarding integration drift under continuous, unbroken vibration bands.
- The feasibility of porting this logic directly into an autopilot sensor pipeline before or parallel to the main EKF.
Full source code, math details, and simulation plots are here: GitHub - parth2152012/noise_cancler · GitHub